PhD student in Mechanical Engineering at Columbia University
I'm a fourth-year PhD student in the ROAM lab advised by Matei Ciocarlie and funded as an NSF GRFP Fellow (2025). I am interested in rehabilitative and assistive robotics and autonomous robotic dexterity.
I received my BS in Bioengineering at Caltech in 2023 and attended Trinity School in NYC.
Resume
Email: k a t e l y n . l e e @ c o l u m b i a . e d u
News
Research
-
Rehabilitative and Assistive Robotics
MyHand is a wearable orthosis device for stroke survivors with spastic hypertonia to assist in hand opening. Currently, I am working in collaboration with CHARM Lab at Stanford University to incorporate vibrotactile stimulation into the device and designing finger splints to better support and assist finger extension.
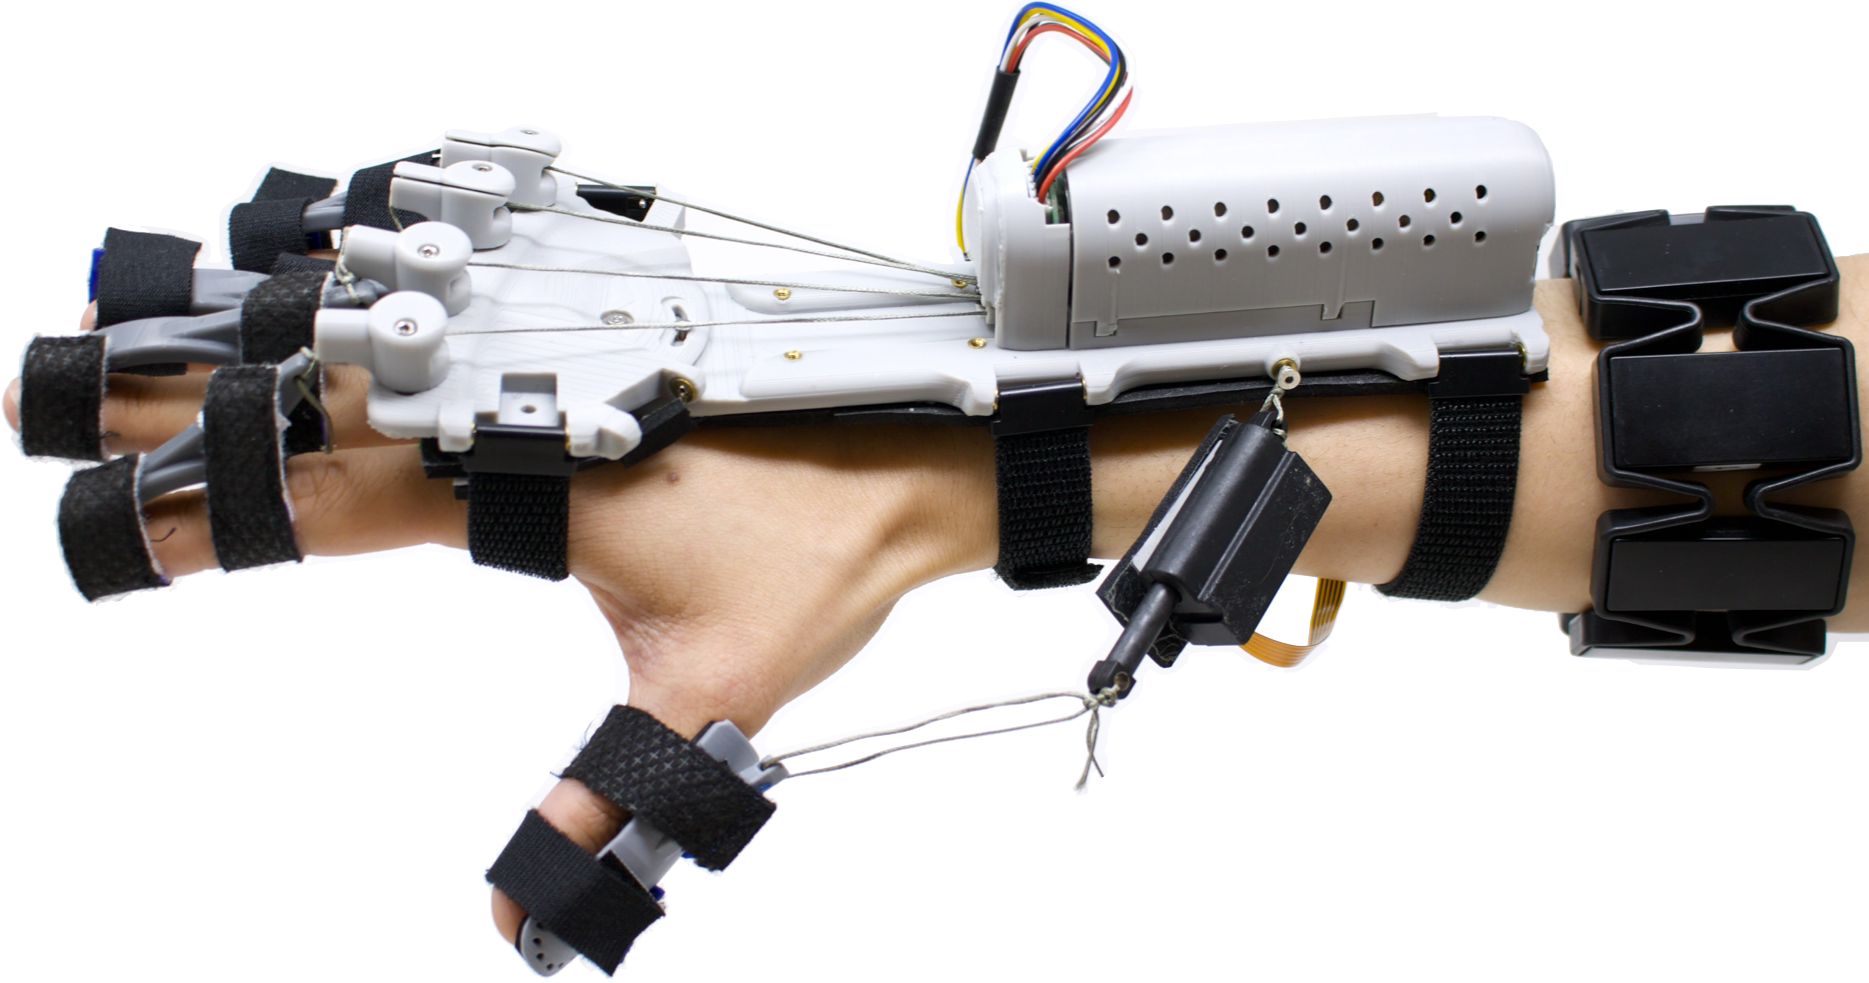
MyHand orthosis
-
Autonomous Robotic Dexterity
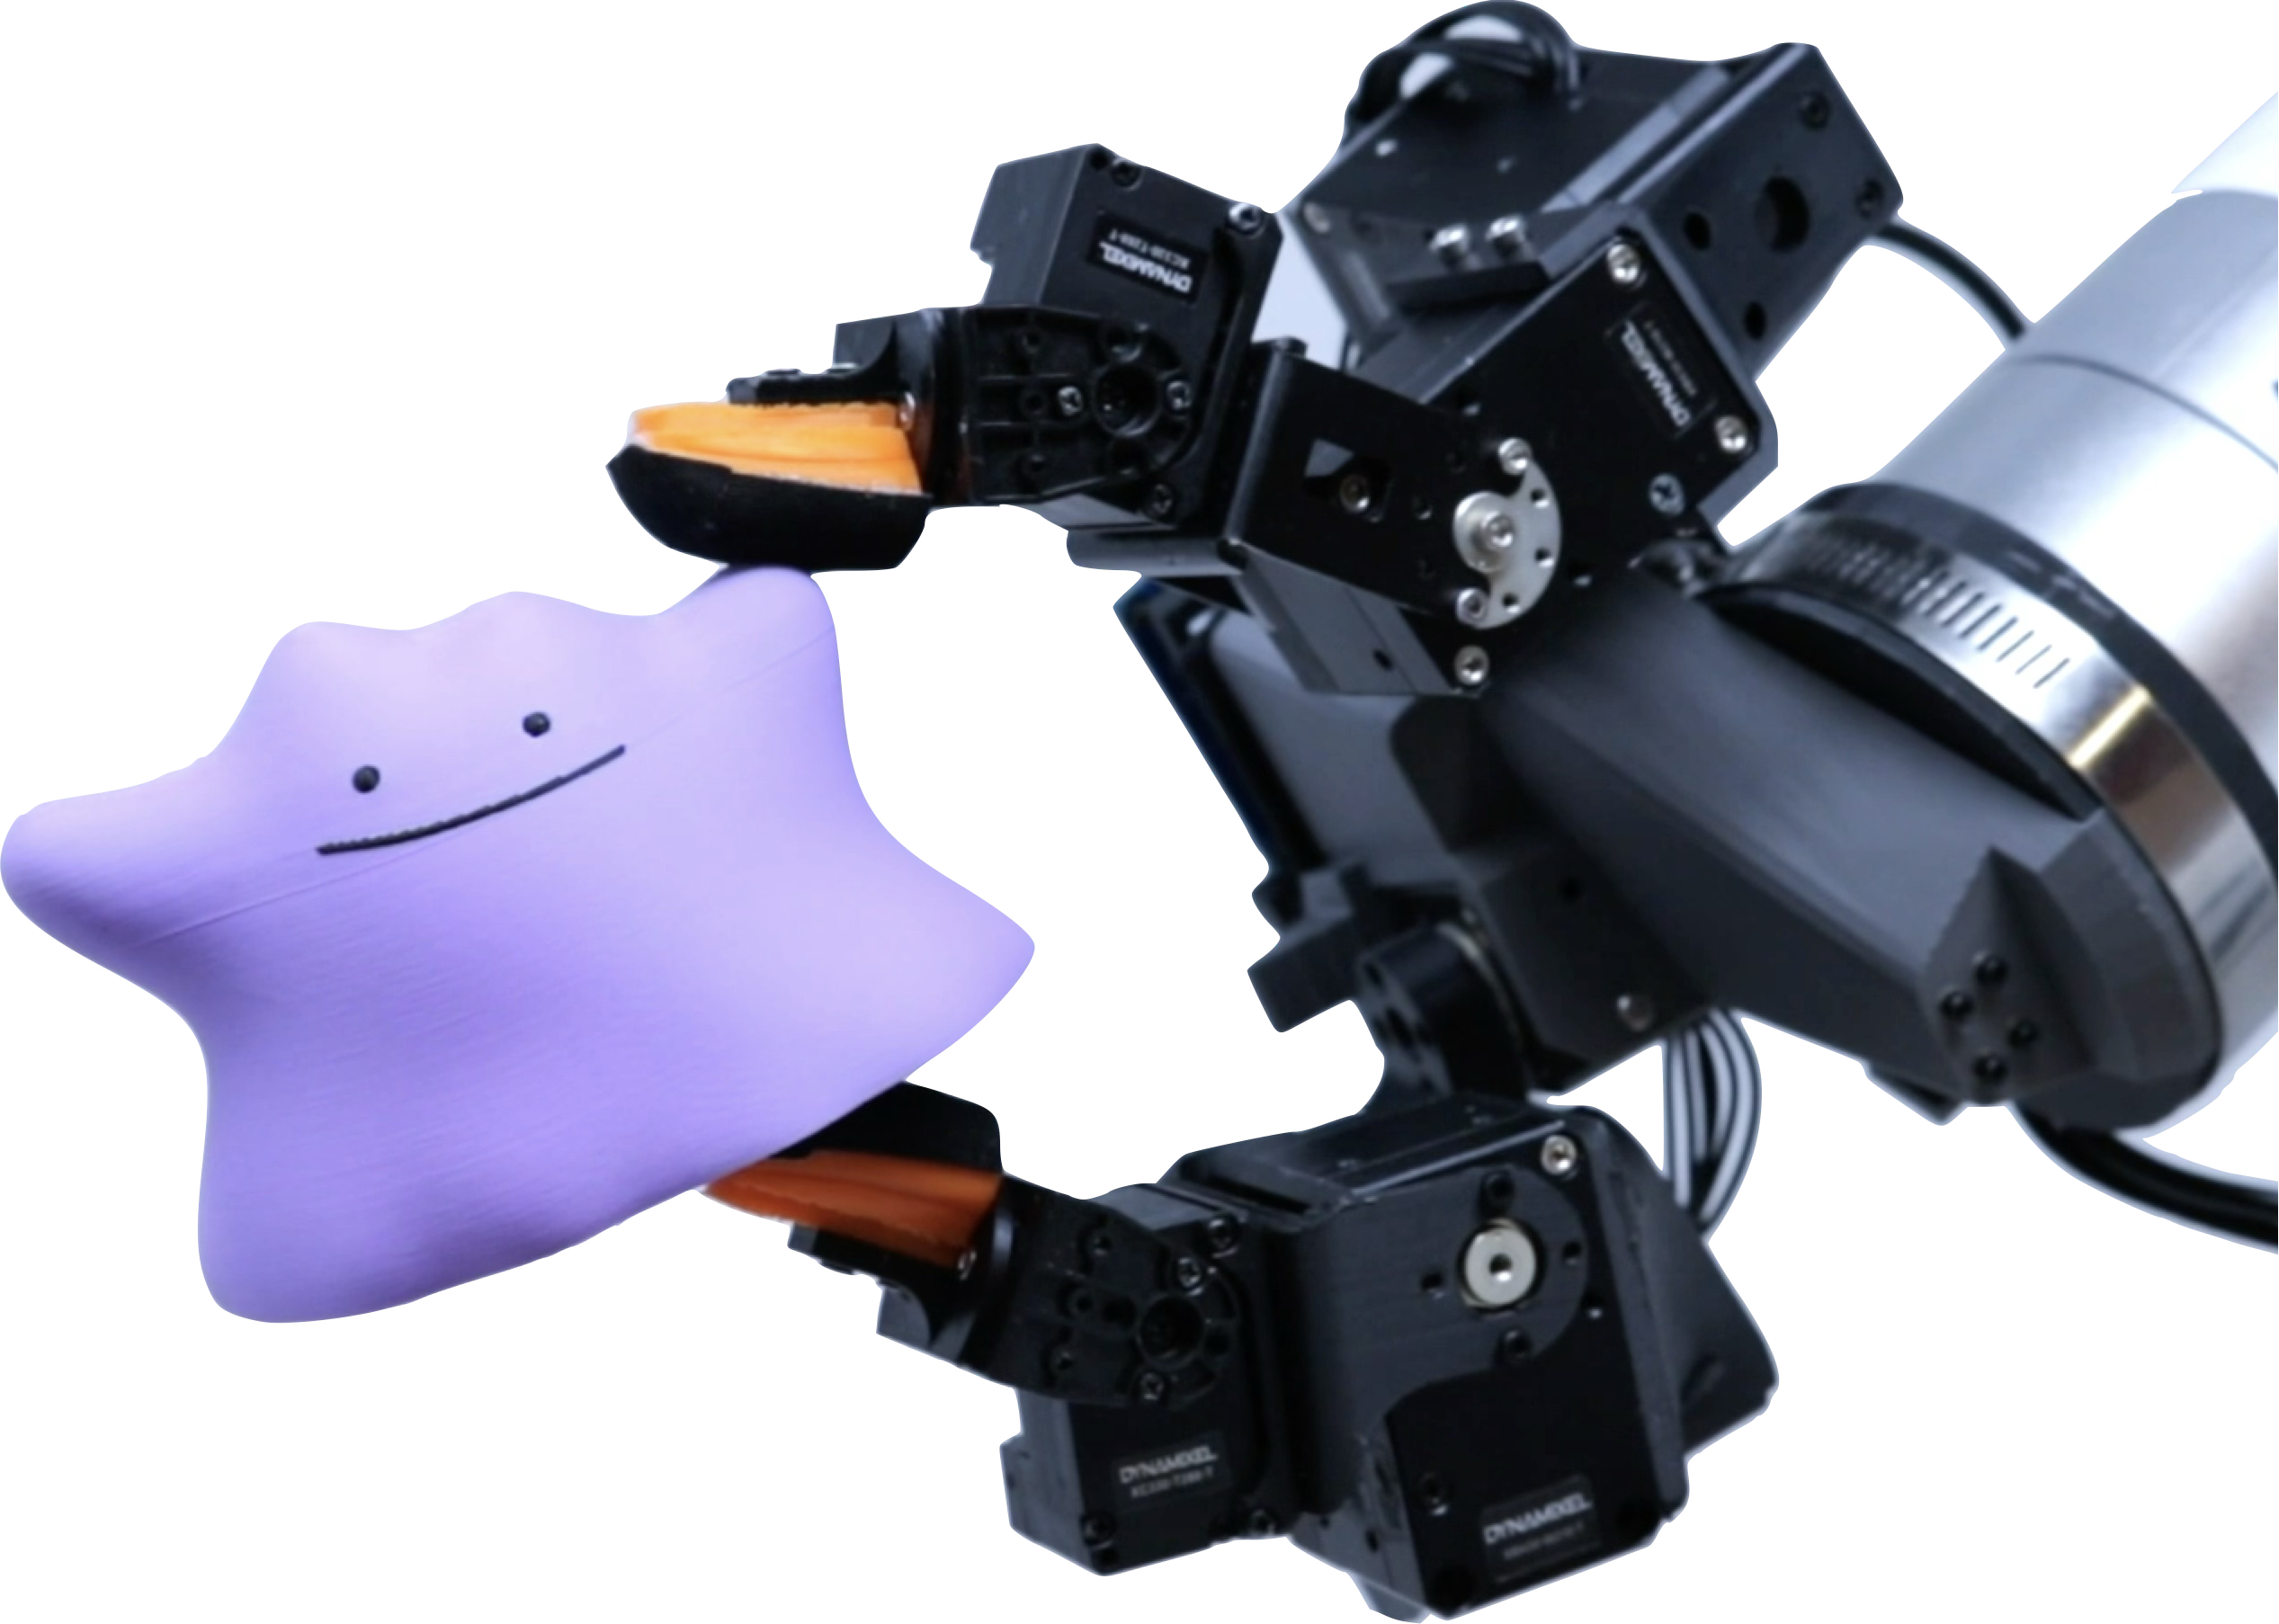
DITTO is a two-fingered robot hand and exoskeleton system for dexterous data collection with joint-level, force feedback. This leader-follower system enables both teleoperation and handheld data collection via anatomically-inspired, 1:1 kinematic equivalency. Data collected with DITTO can be used to train policies for dexterous, contact-rich tasks.
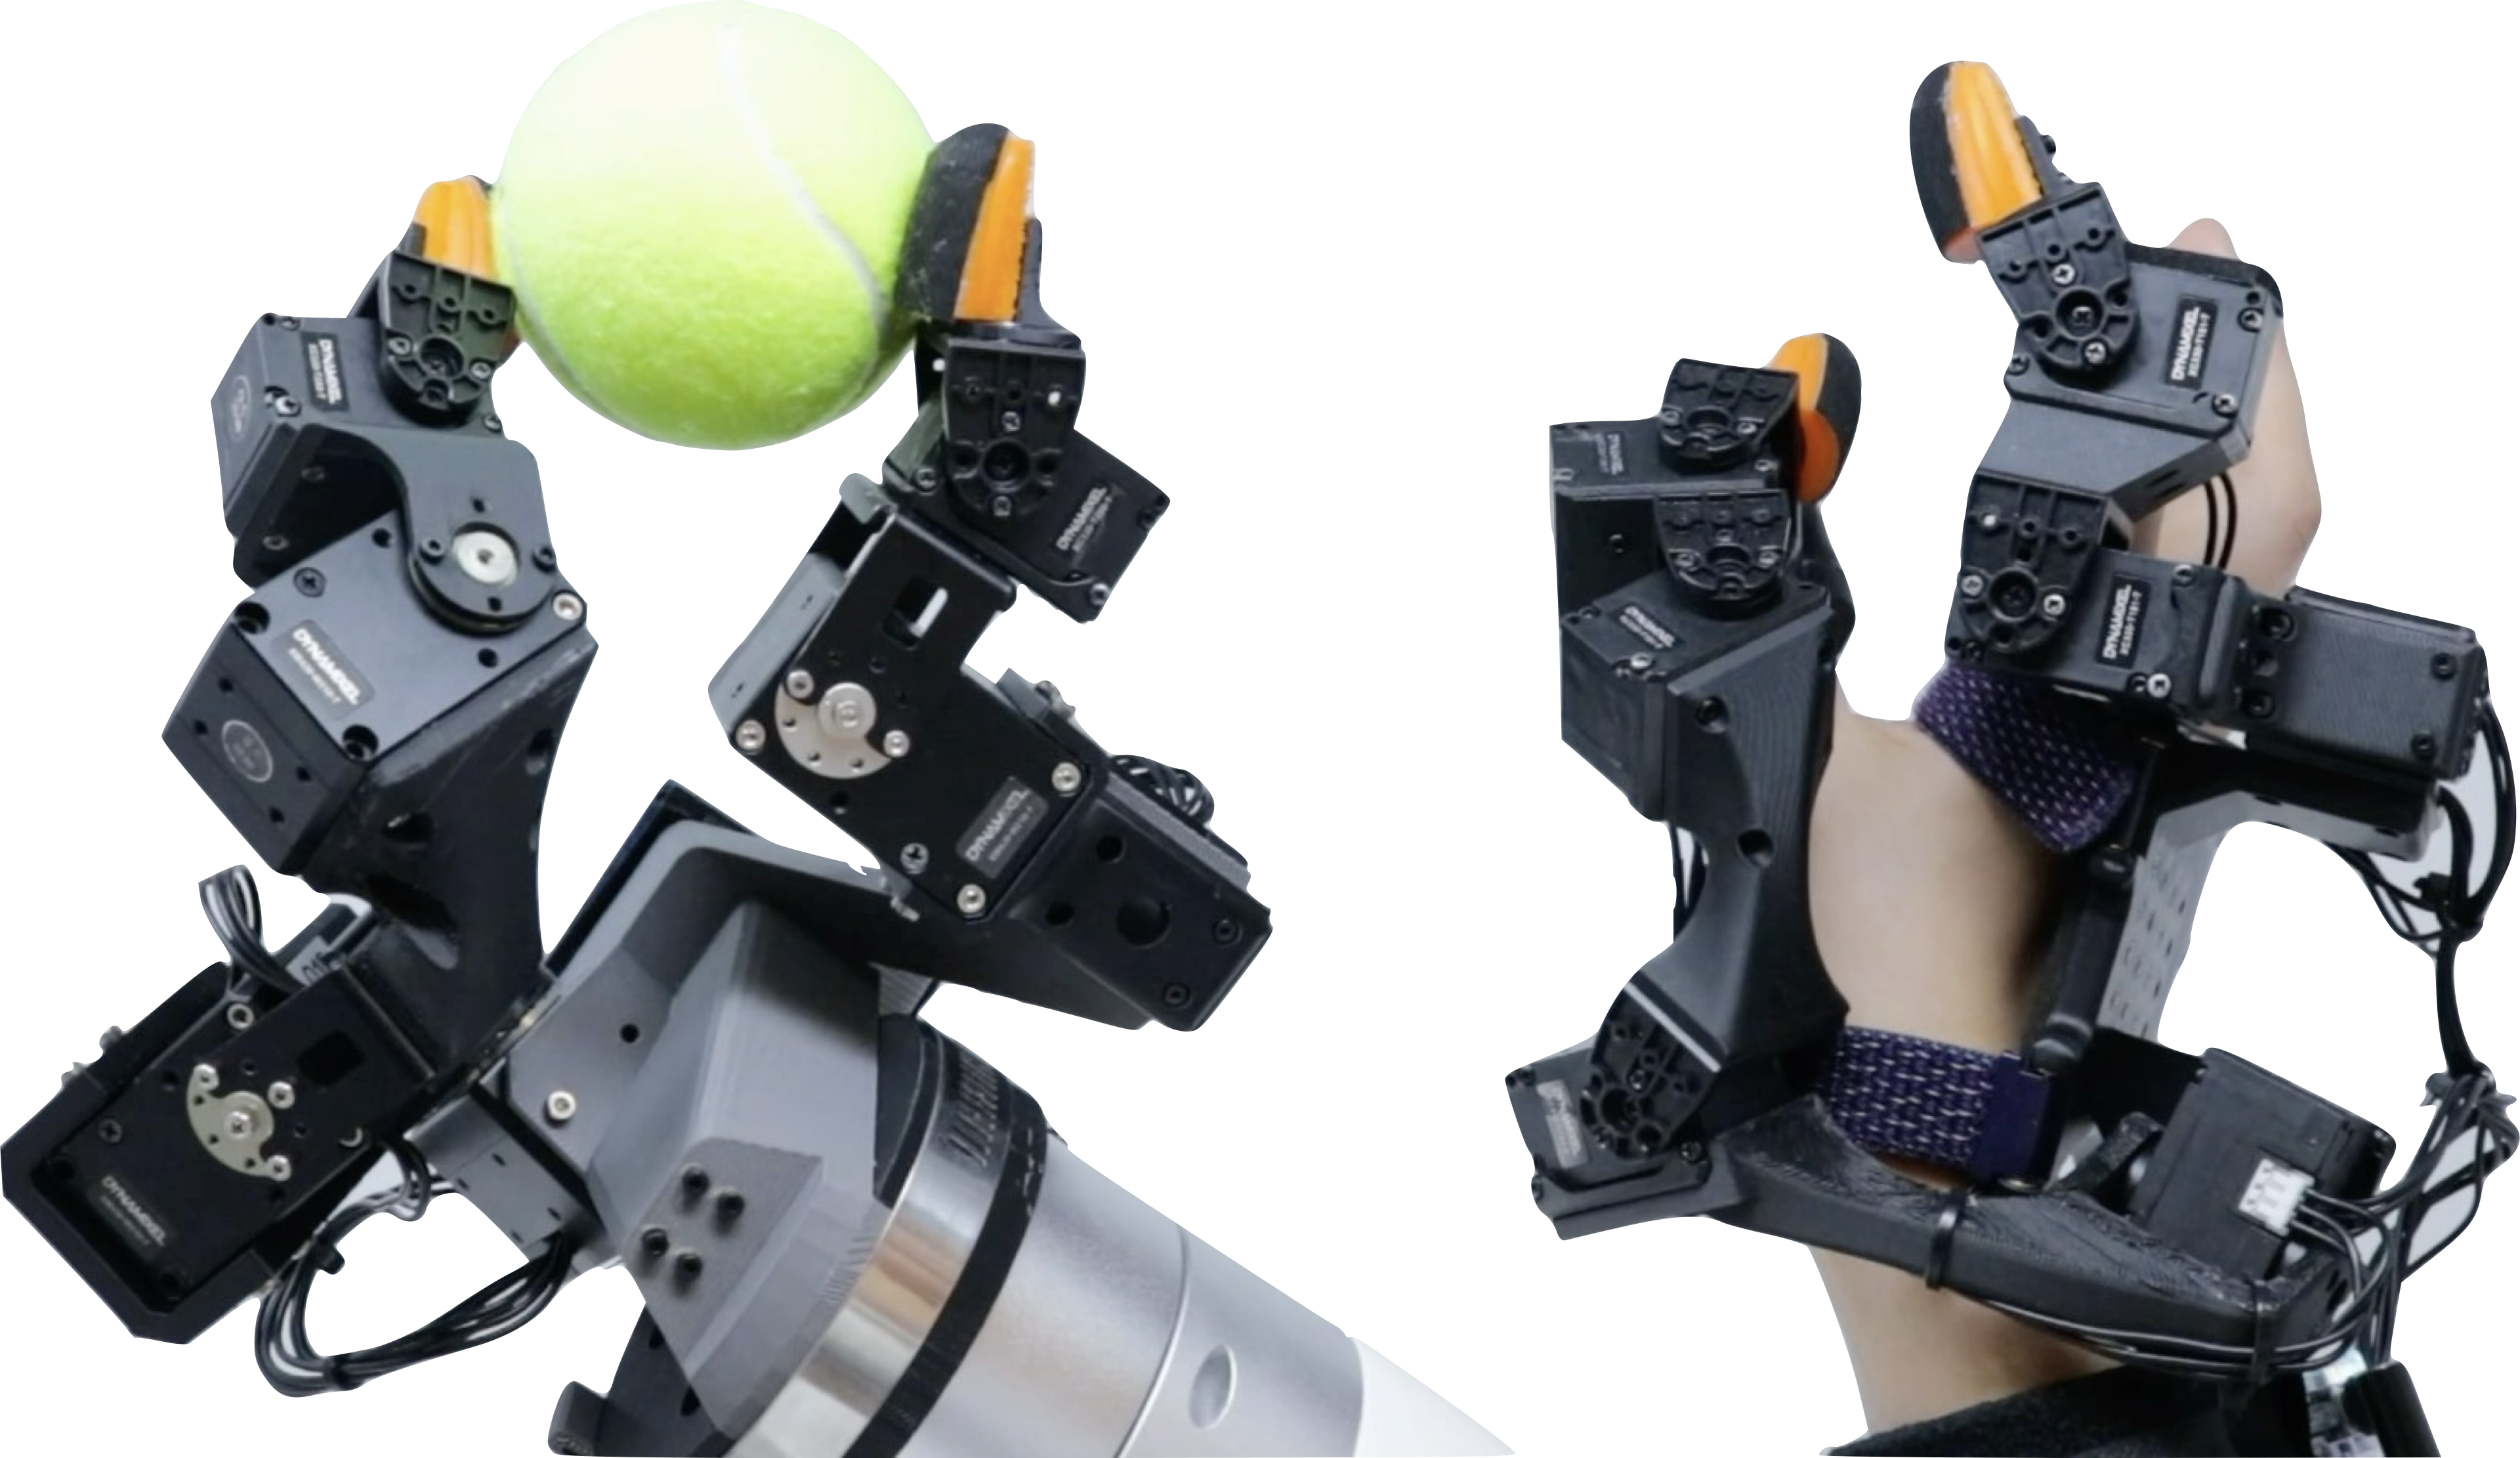
DITTO follower hand and leader exo
Publications & Posters
* indicates equal contribution
-
-
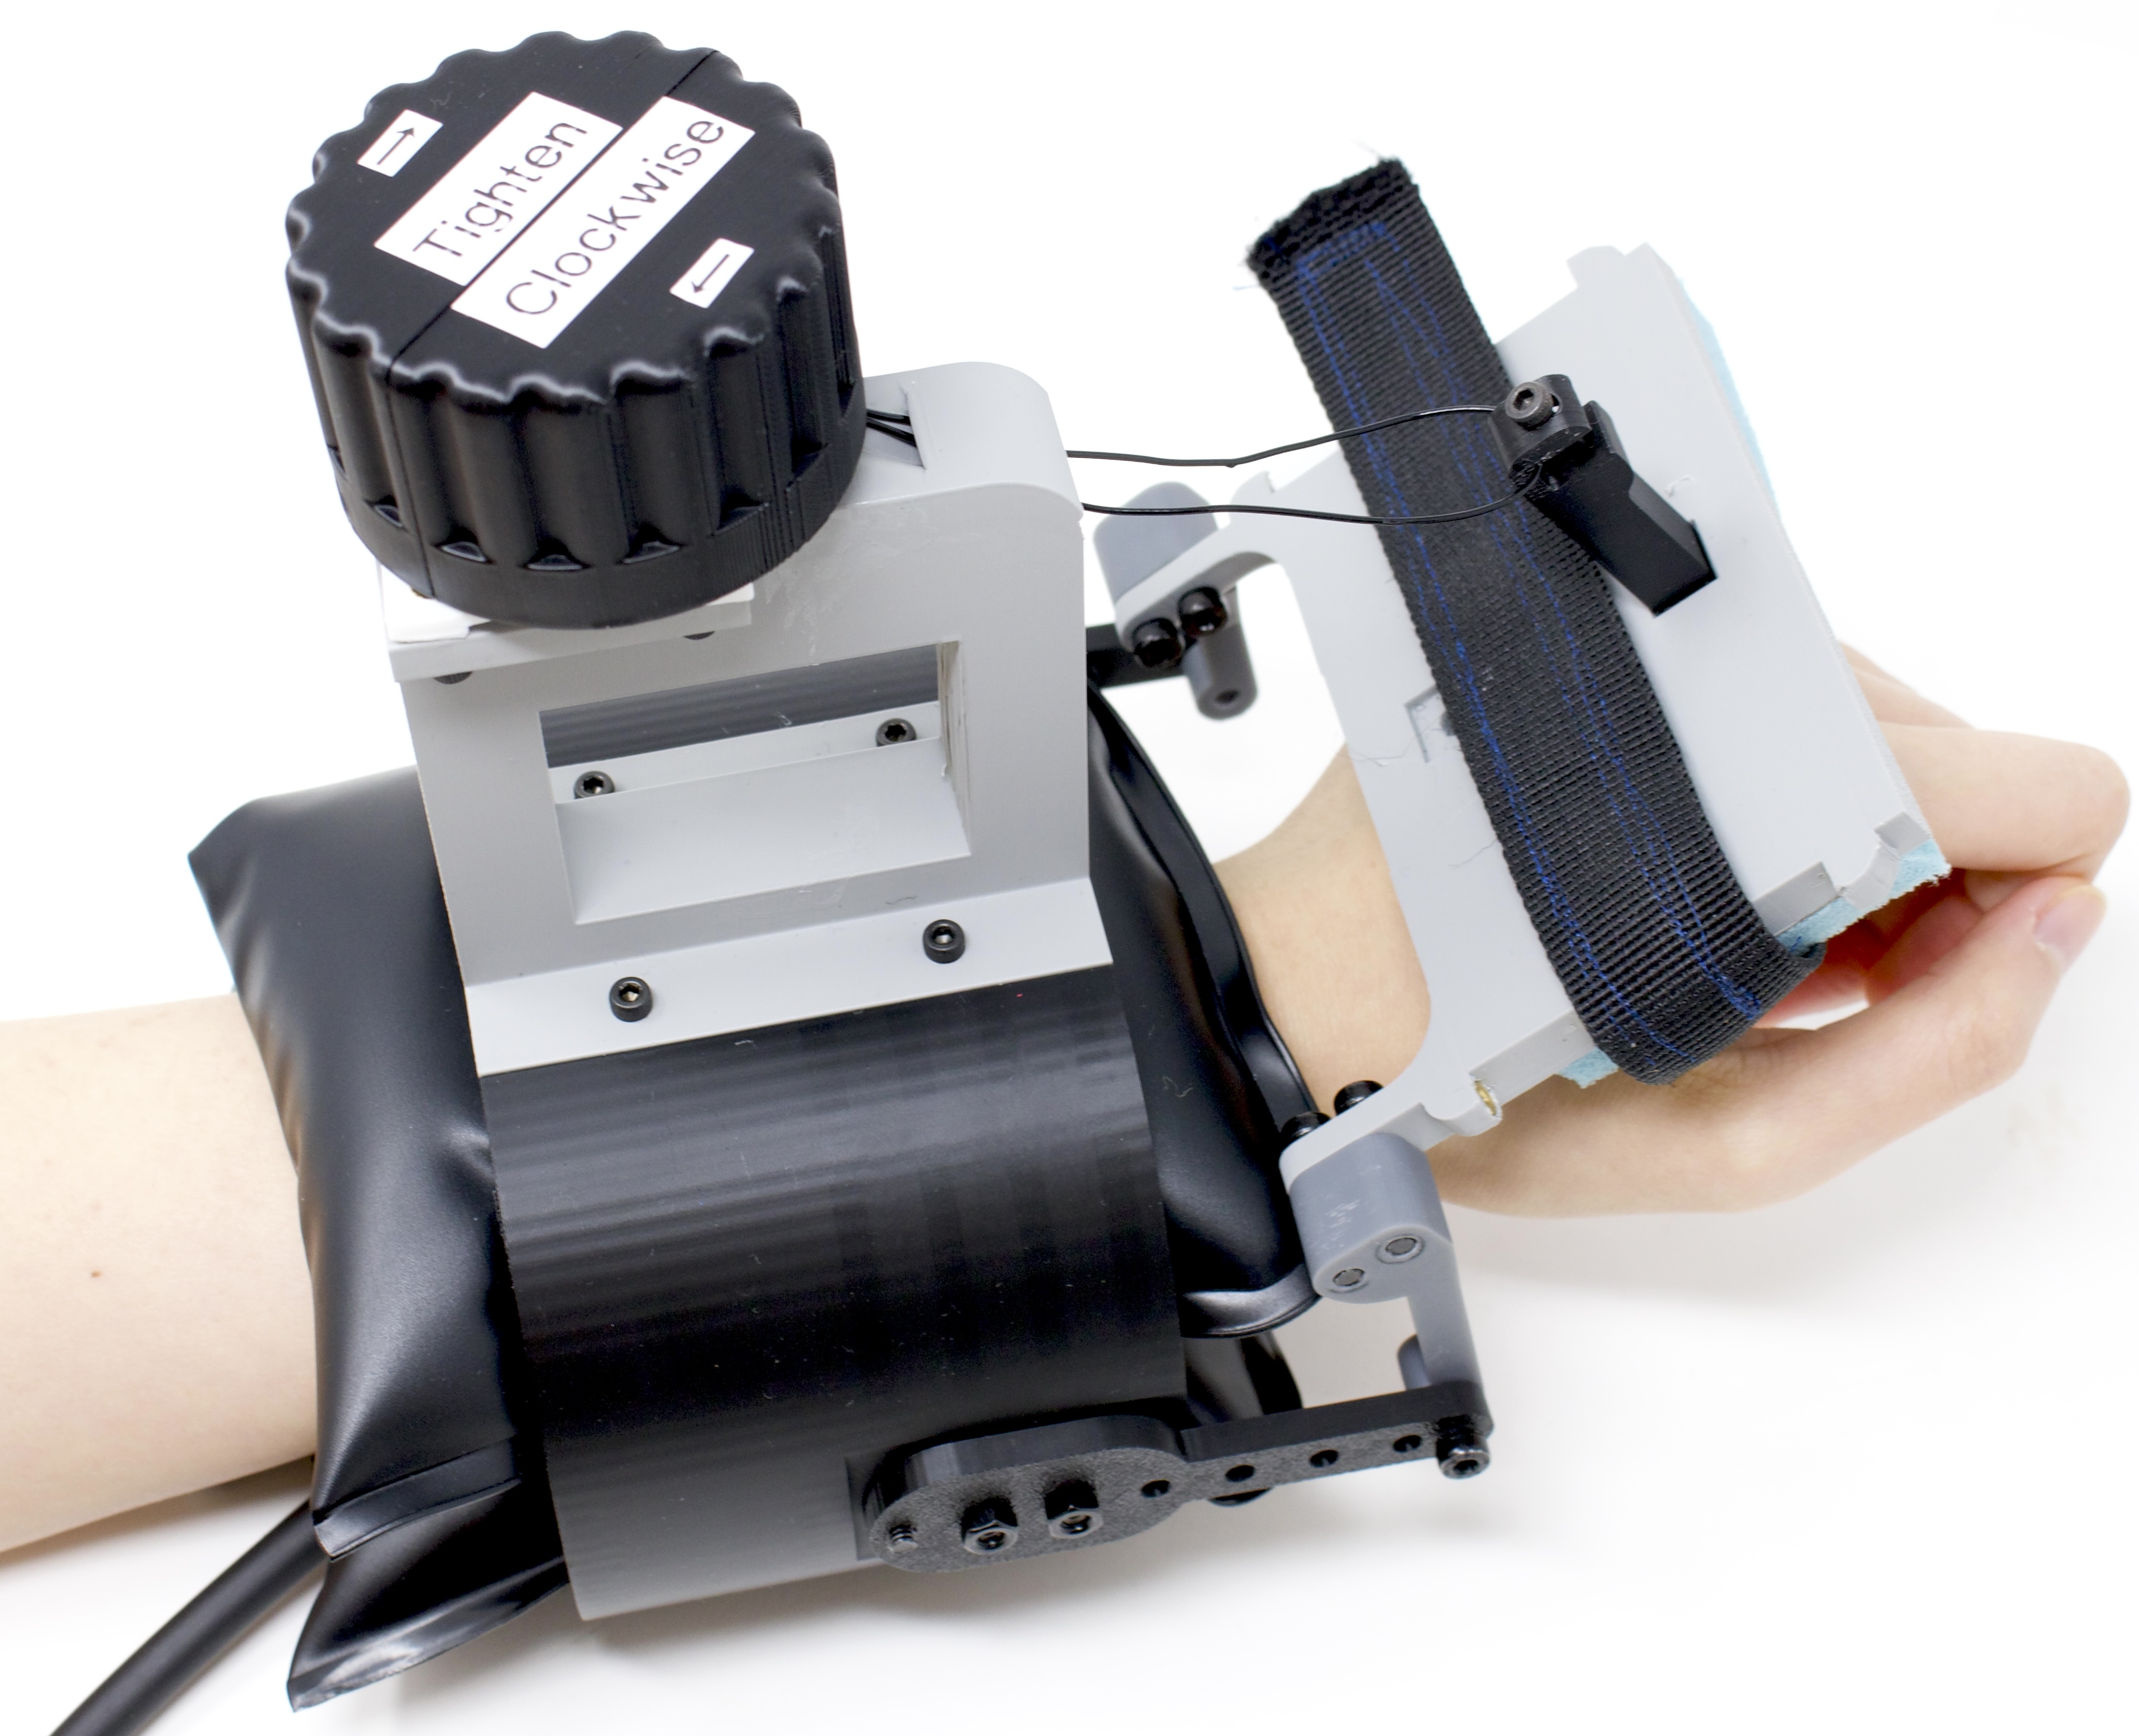 SUREHand: A Self-Stretching Device for One-Handed Use by Stroke Survivors
Accepted to fast-track publication in IEEE Transactions on Medical Robotics and Bionics (T-MRB)
🏆 Winner of 1st place Best Student Paper Award at BioRob 2026!
-
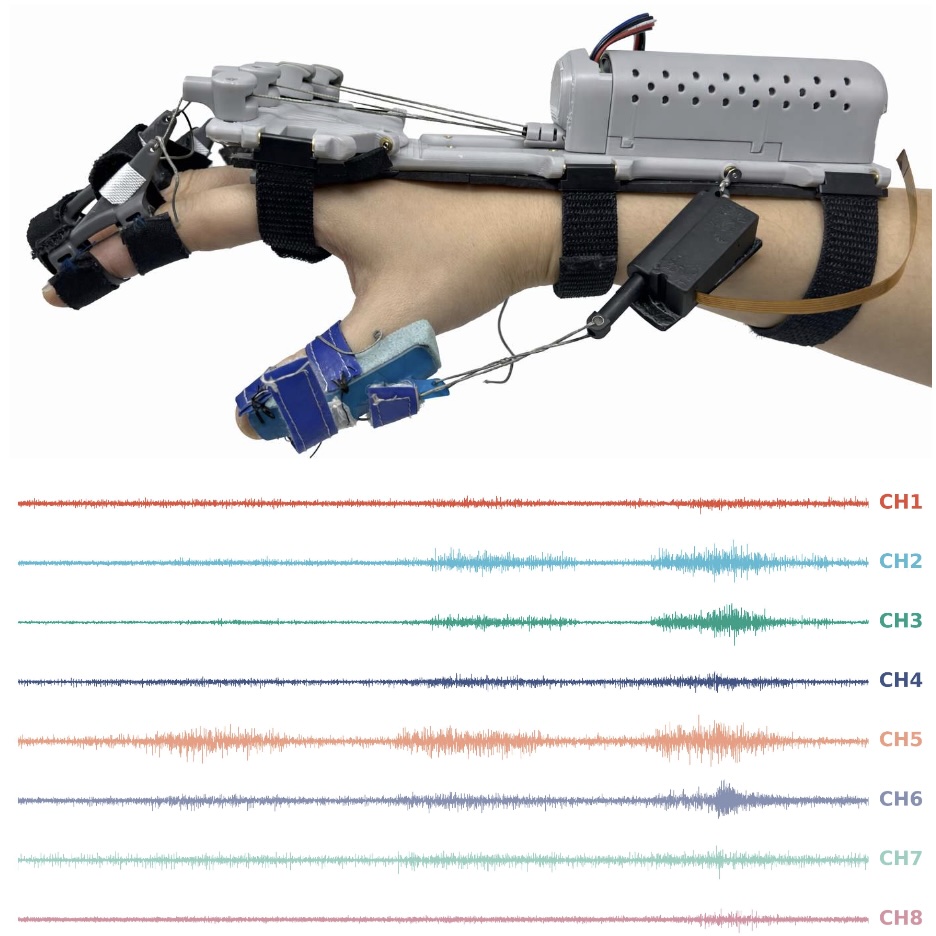 ReactEMG Stroke: Healthy-to-Stroke Few-shot Adaptation for sEMG-Based Intent Detection
2026 IEEE RAS/EMBS Intl. Conference on Biomedical Robotics and Biomechatronics (BioRob)
-
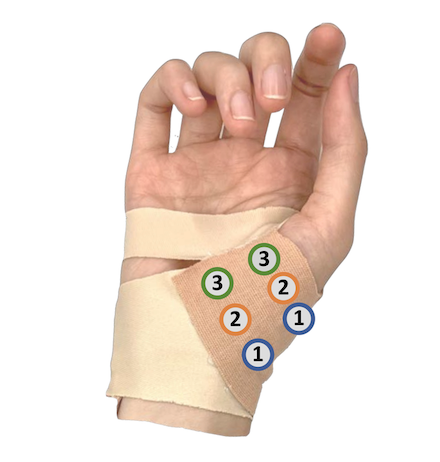 Fabric Sensing of Intrinsic Hand Muscle Activity
2025 IEEE/RAS-EMBS International Conference on Rehabilitation Robotics (ICORR)
-
 Volitional Control of the Paretic Hand Post-Stroke Increases Finger Stiffness and Resistance to Robot-Assisted Movement
2024 IEEE RAS/EMBS Intl. Conference on Biomedical Robotics and Biomechatronics (BioRob)
-
Fabric EMG Sensing for Robotic Orthosis Control
Poster at Biorob 2024 Workshop: Building Responsive Body-Machine Interfaces With Biosignals and Robotic Exoskeletons
-
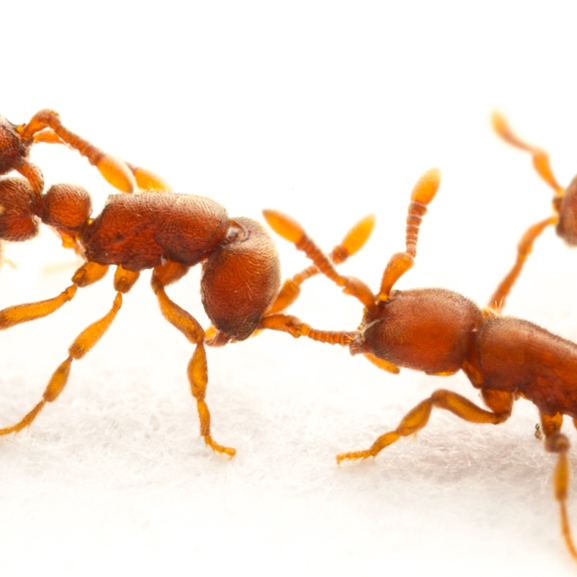 Ancient Feeding-Related Neuropeptides Regulate Alloparenting in Ants
Nature, vol. 656, pp. 948–956 (2026)
Personal Project
-
SolidWorks Relative Transform Macro
A Solidworks VBA macro for Part files to create coordinate frames from 4x4 transforms and calculate relative transforms between coordinate frames. Created out of a desire to easily define complex 3D rotations from 6dof position and orientation data from /tf in Solidworks.